What Makes Structured Episodic Retrieval Robust to Noisy Query Cues? A Controlled Study
Authors withheld during review
Under review, 2026
Research / Technology & Engineering
We build AI systems that stay reliable when their inputs are uncertain: perception that makes mistakes, memories that must be searched with vague cues, and cities observed through sparse sensors.
Technology research at OSiV is carried out with our partner group ViSO. The common thread is structure and calibrated uncertainty: instead of trusting one prediction, our systems keep structured records with confidences and let reliable evidence outweigh unreliable evidence.
We work on video understanding, memory for AI agents and spatio-temporal learning, and evaluate on public benchmarks with controlled noise so that robustness can be measured, not assumed.
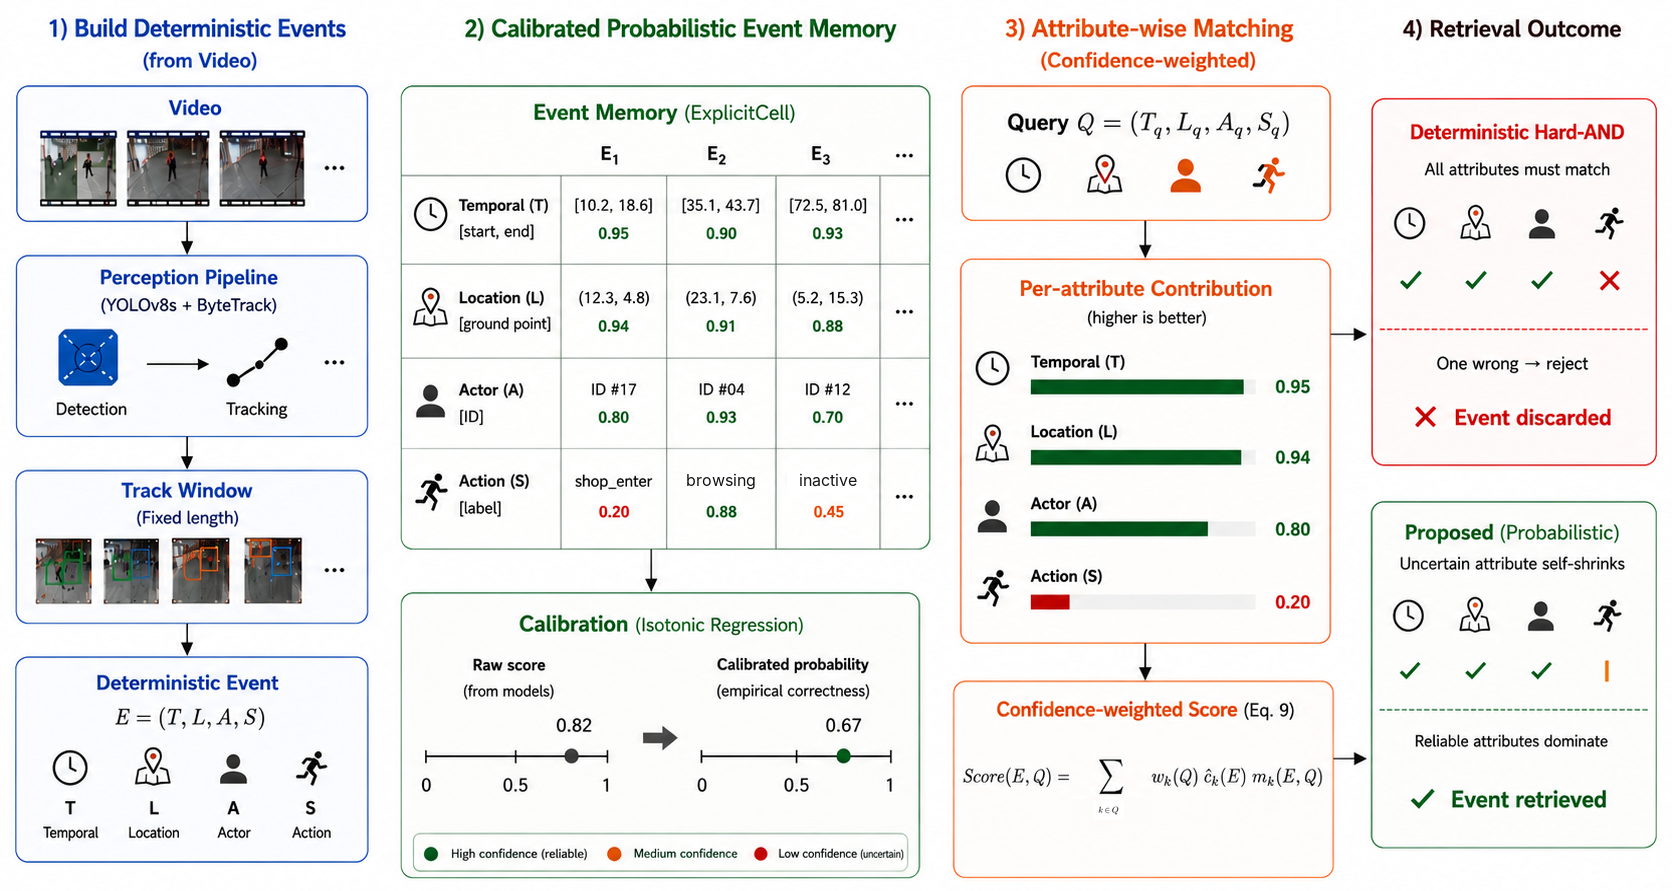
How can a retrieval system keep finding events when detectors, trackers and action classifiers make mistakes?
Long videos are summarised as structured events (time, location, actor, action). We treat the correctness of each attribute as a latent variable and calibrate its confidence, so one misrecognised cue no longer discards an event.
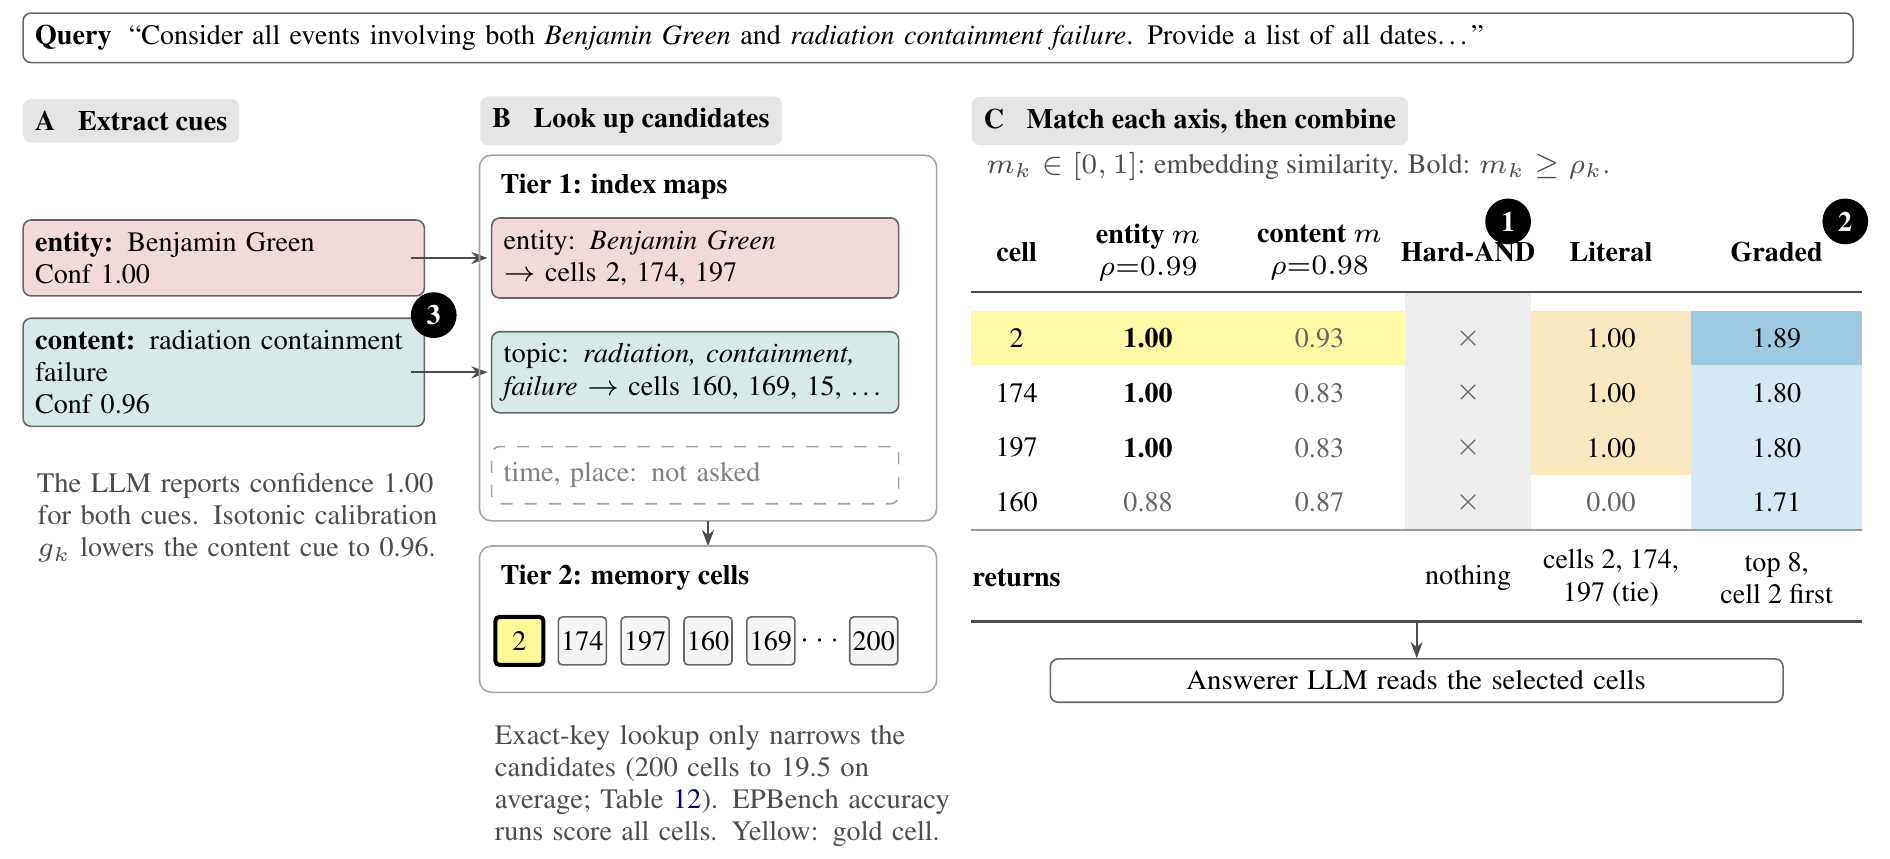
What makes structured episodic retrieval robust when the query cues themselves are noisy?
LLM agents need to recall past episodes from partial and sometimes wrong cues. We study, under controlled noise, how confidence-aware matching across several memory axes compares with strict matching and embedding search.
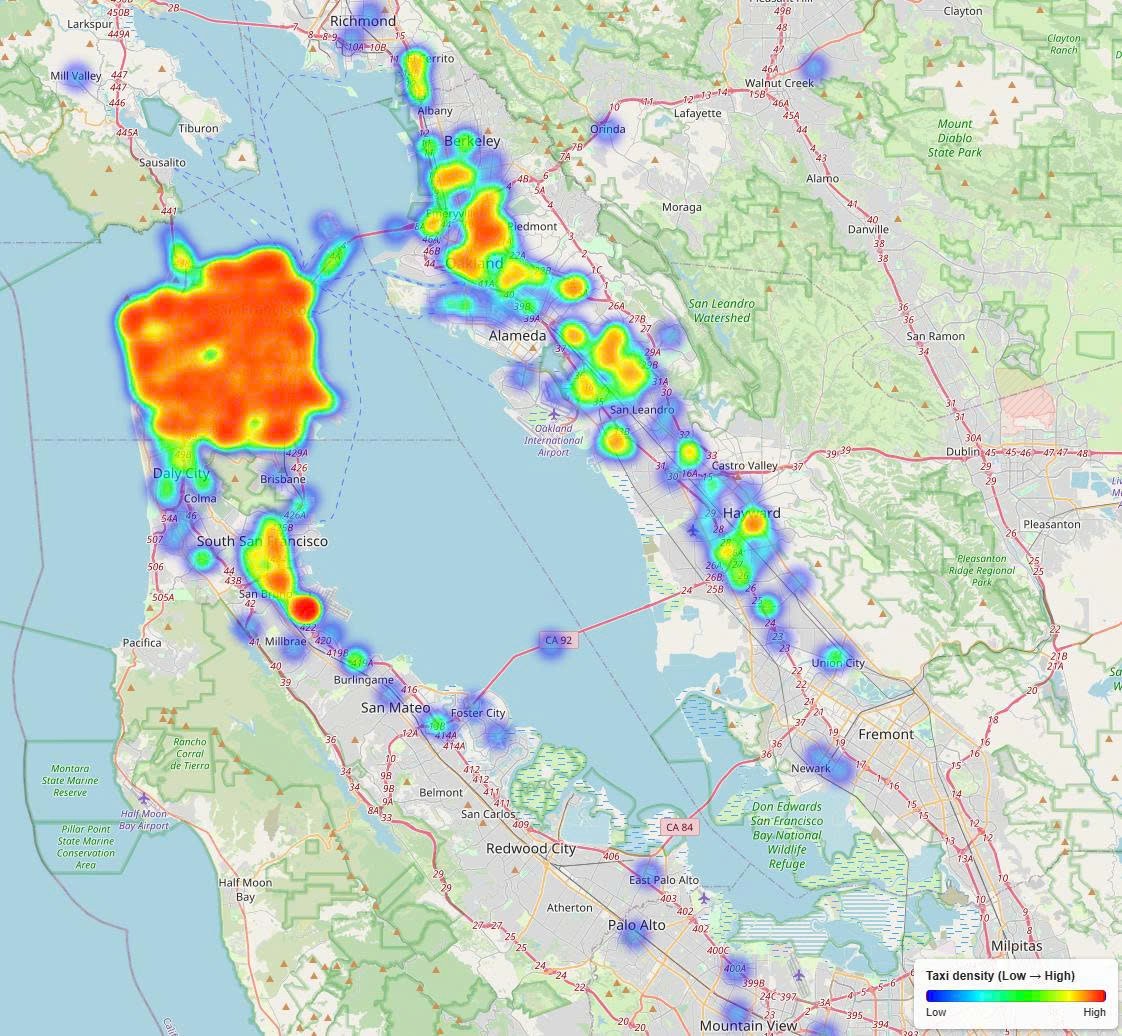
How can sparse road sensors and dense vehicle trajectories be combined to predict traffic across a whole city?
Graph neural networks fuse loop-detector data with taxi GPS trajectories; pattern-driven pseudo-labels fill in roads that have no sensor.
See also: Economics, Culture & Society